Basilisk drone in motion.

01Prompt

An original six-legged war-mech. Chipped ochre armor, oily joints and a low industrial chassis. A coordinated walk through a worn concrete service yard.
Full prompt
Use case: stylized-concept.
Asset type: one cinematic raster concept frame that will be used unchanged for both image-to-video and image-to-3D reconstruction.

Create ONE original six-legged cyberpunk war-mech in a believable grungy industrial style, with broad aesthetic influences from Cyberpunk 2077 and Ghost in the Shell, without copying a recognizable existing machine or character.

Scene/backdrop: a flat, worn, dry concrete service yard, a subdued distant industrial wall and warehouses, subtle tiny cyan and red environmental light hints. Empty space around the subject, no other vehicles or characters. Diffuse overcast daylight, crisp clear visibility, high contrast between the mechanical legs and the quiet background.

Subject: a squat elongated armored central hull, long axis pointing toward SCREEN RIGHT, with a compact forward gun-and-sensor housing. Chipped industrial ochre-yellow/orange armor and dark graphite structural metal, chunky mechanical hip joints, oily bearings, scratches, exposed hydraulic actuators, asymmetric welded repair plates, a few modest cyan and red sensor optics. Heavy utilitarian hard-surface mechanical construction; matte rough materials; dense but plausible detail.

HIGHEST PRIORITY ANATOMICAL CONSTRAINT: the machine has exactly SIX separate articulated WEIGHT-BEARING LEGS, arranged as THREE distinct legs on the near side of the hull and THREE distinct legs on the far side. Each leg is a complete rigid two- or three-segment insectoid mechanical assembly, attached at its own hip and ending in its own broad flat ground pad. SIX hips, SIX complete leg chains, SIX separate feet, no more and no fewer. All six feet must be visible and countable, with open background gaps between all six leg silhouettes. Make the three far-side legs clearly readable, not hidden behind the three near-side legs. Stagger the far-side leg poses along the hull so their full lower segments and ground pads appear in the open gaps between near-side legs. Use a stable widely splayed pose. Do not merge legs, do not imply unseen legs, and do not place any foot behind another foot.

Composition/framing: horizontal 16:9 image. Full machine uncropped with generous spare travel space on both sides, occupying roughly 65 percent of image width. Camera primarily side-on but elevated enough to see the six separated feet and far side legs, turned about 20 degrees toward the front of the machine. Long hull reads horizontally, front at the right. Frame all legs and ground pads completely. Cinematic concept realism with precise, legible silhouette and sharp material detail.

Avoid: glossy toy styling; organic anatomy; extra arms, limbs, wheels or tracks; dangling cables that could look like additional appendages; green screen; motion-capture suit or markers; people; firing weapons; destruction; smoke; rain; fog; foreground obstacles; occluding debris; text; logos; labels; watermarks.

Concept art prompt · Used to generate the first image.
02Creature

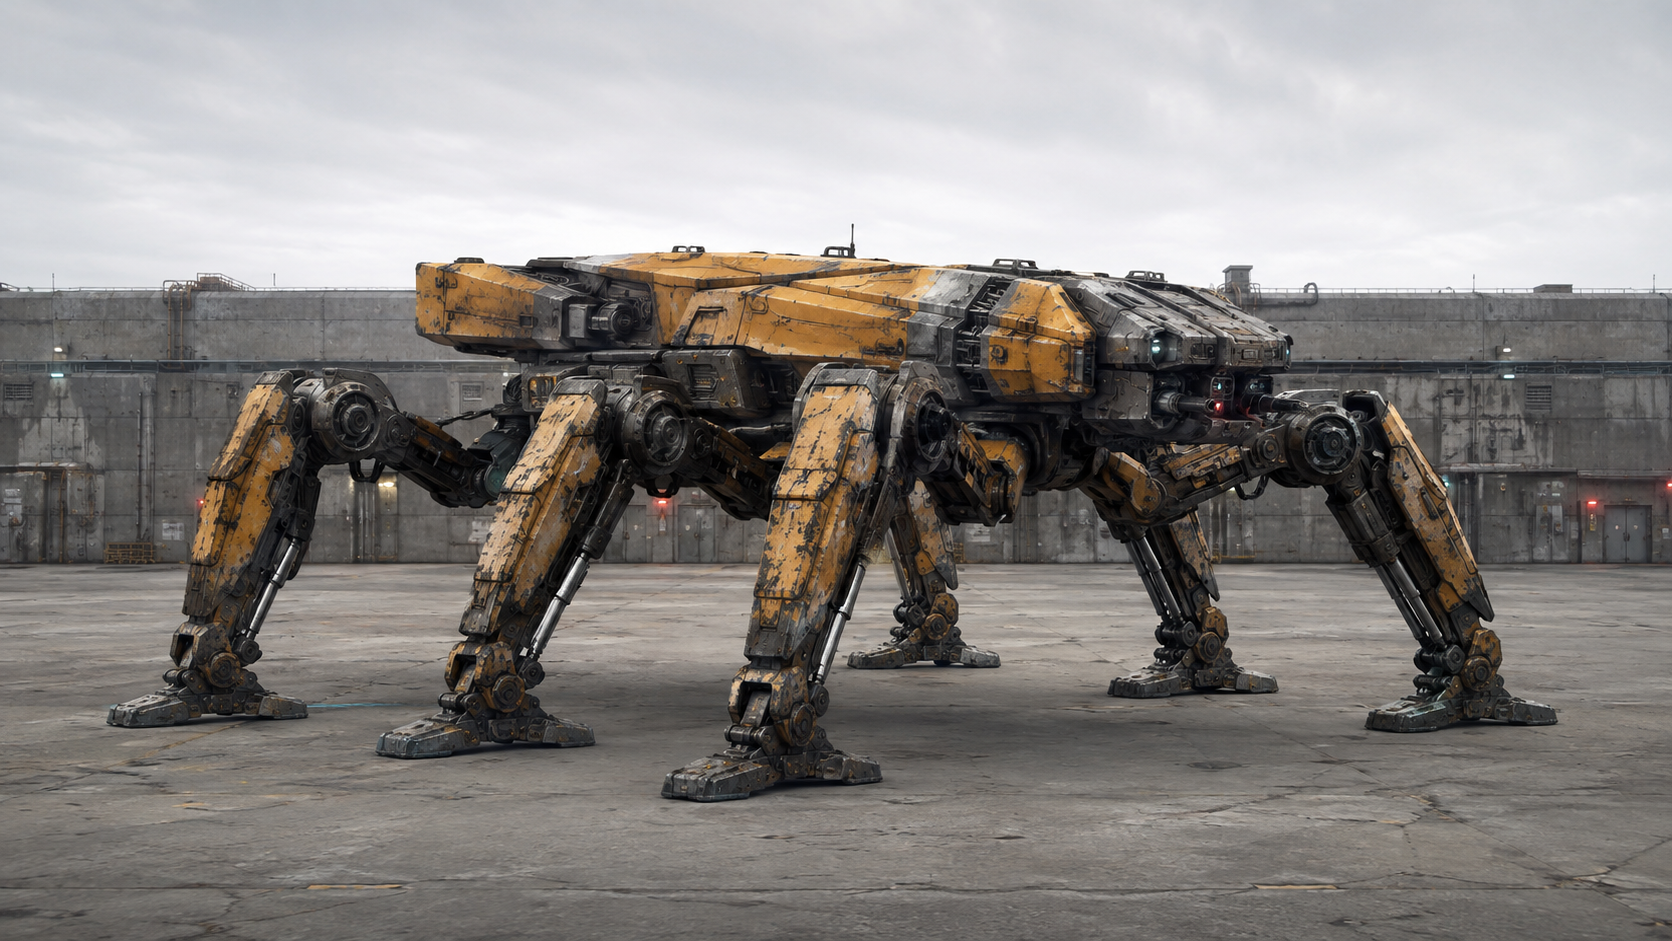
Basilisk drone concept art.
Concept art · ImageGen; original grungy cyberpunk design.

03Tracked video

Tracked video · TAPNext++ 512 + SAM 3. Colors show motion groups; white lines show fitted axes.

04Mesh + texture

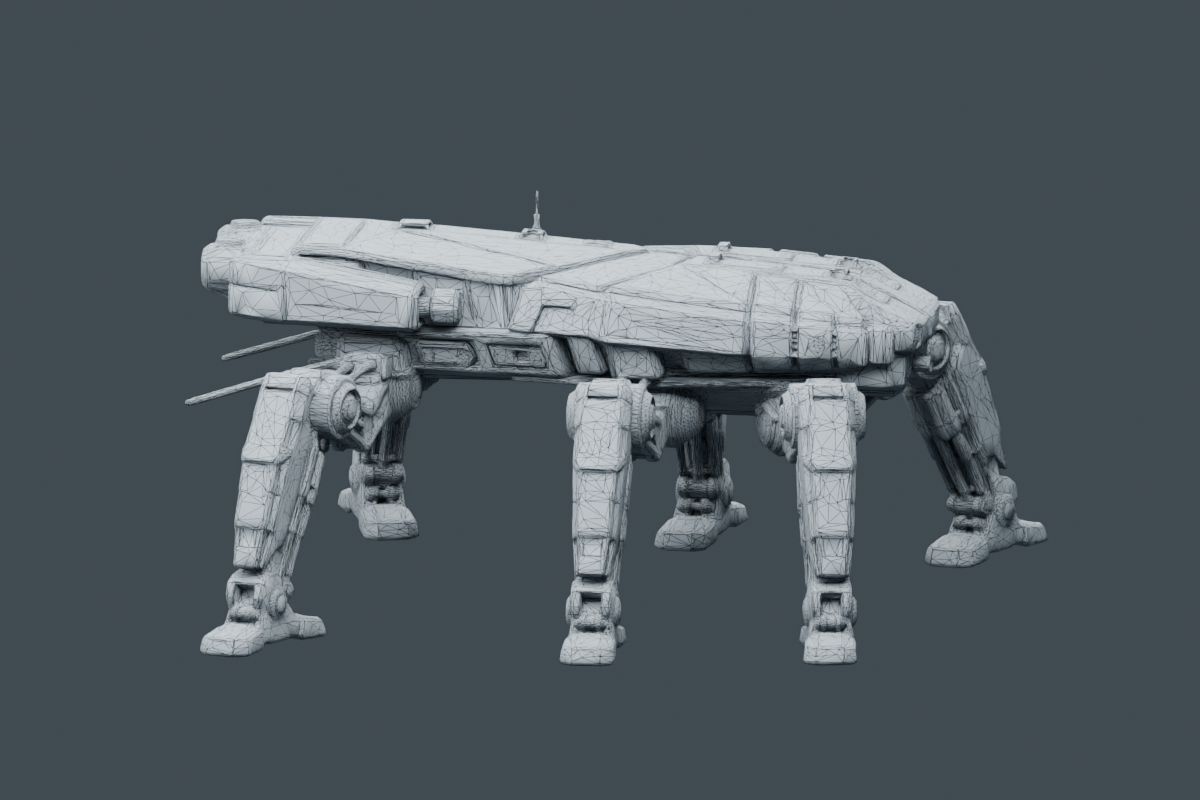
Basilisk drone mesh with its triangle edges visible.
Triangulated mesh · Hunyuan 3D from the reconstruction; rendered in Blender.
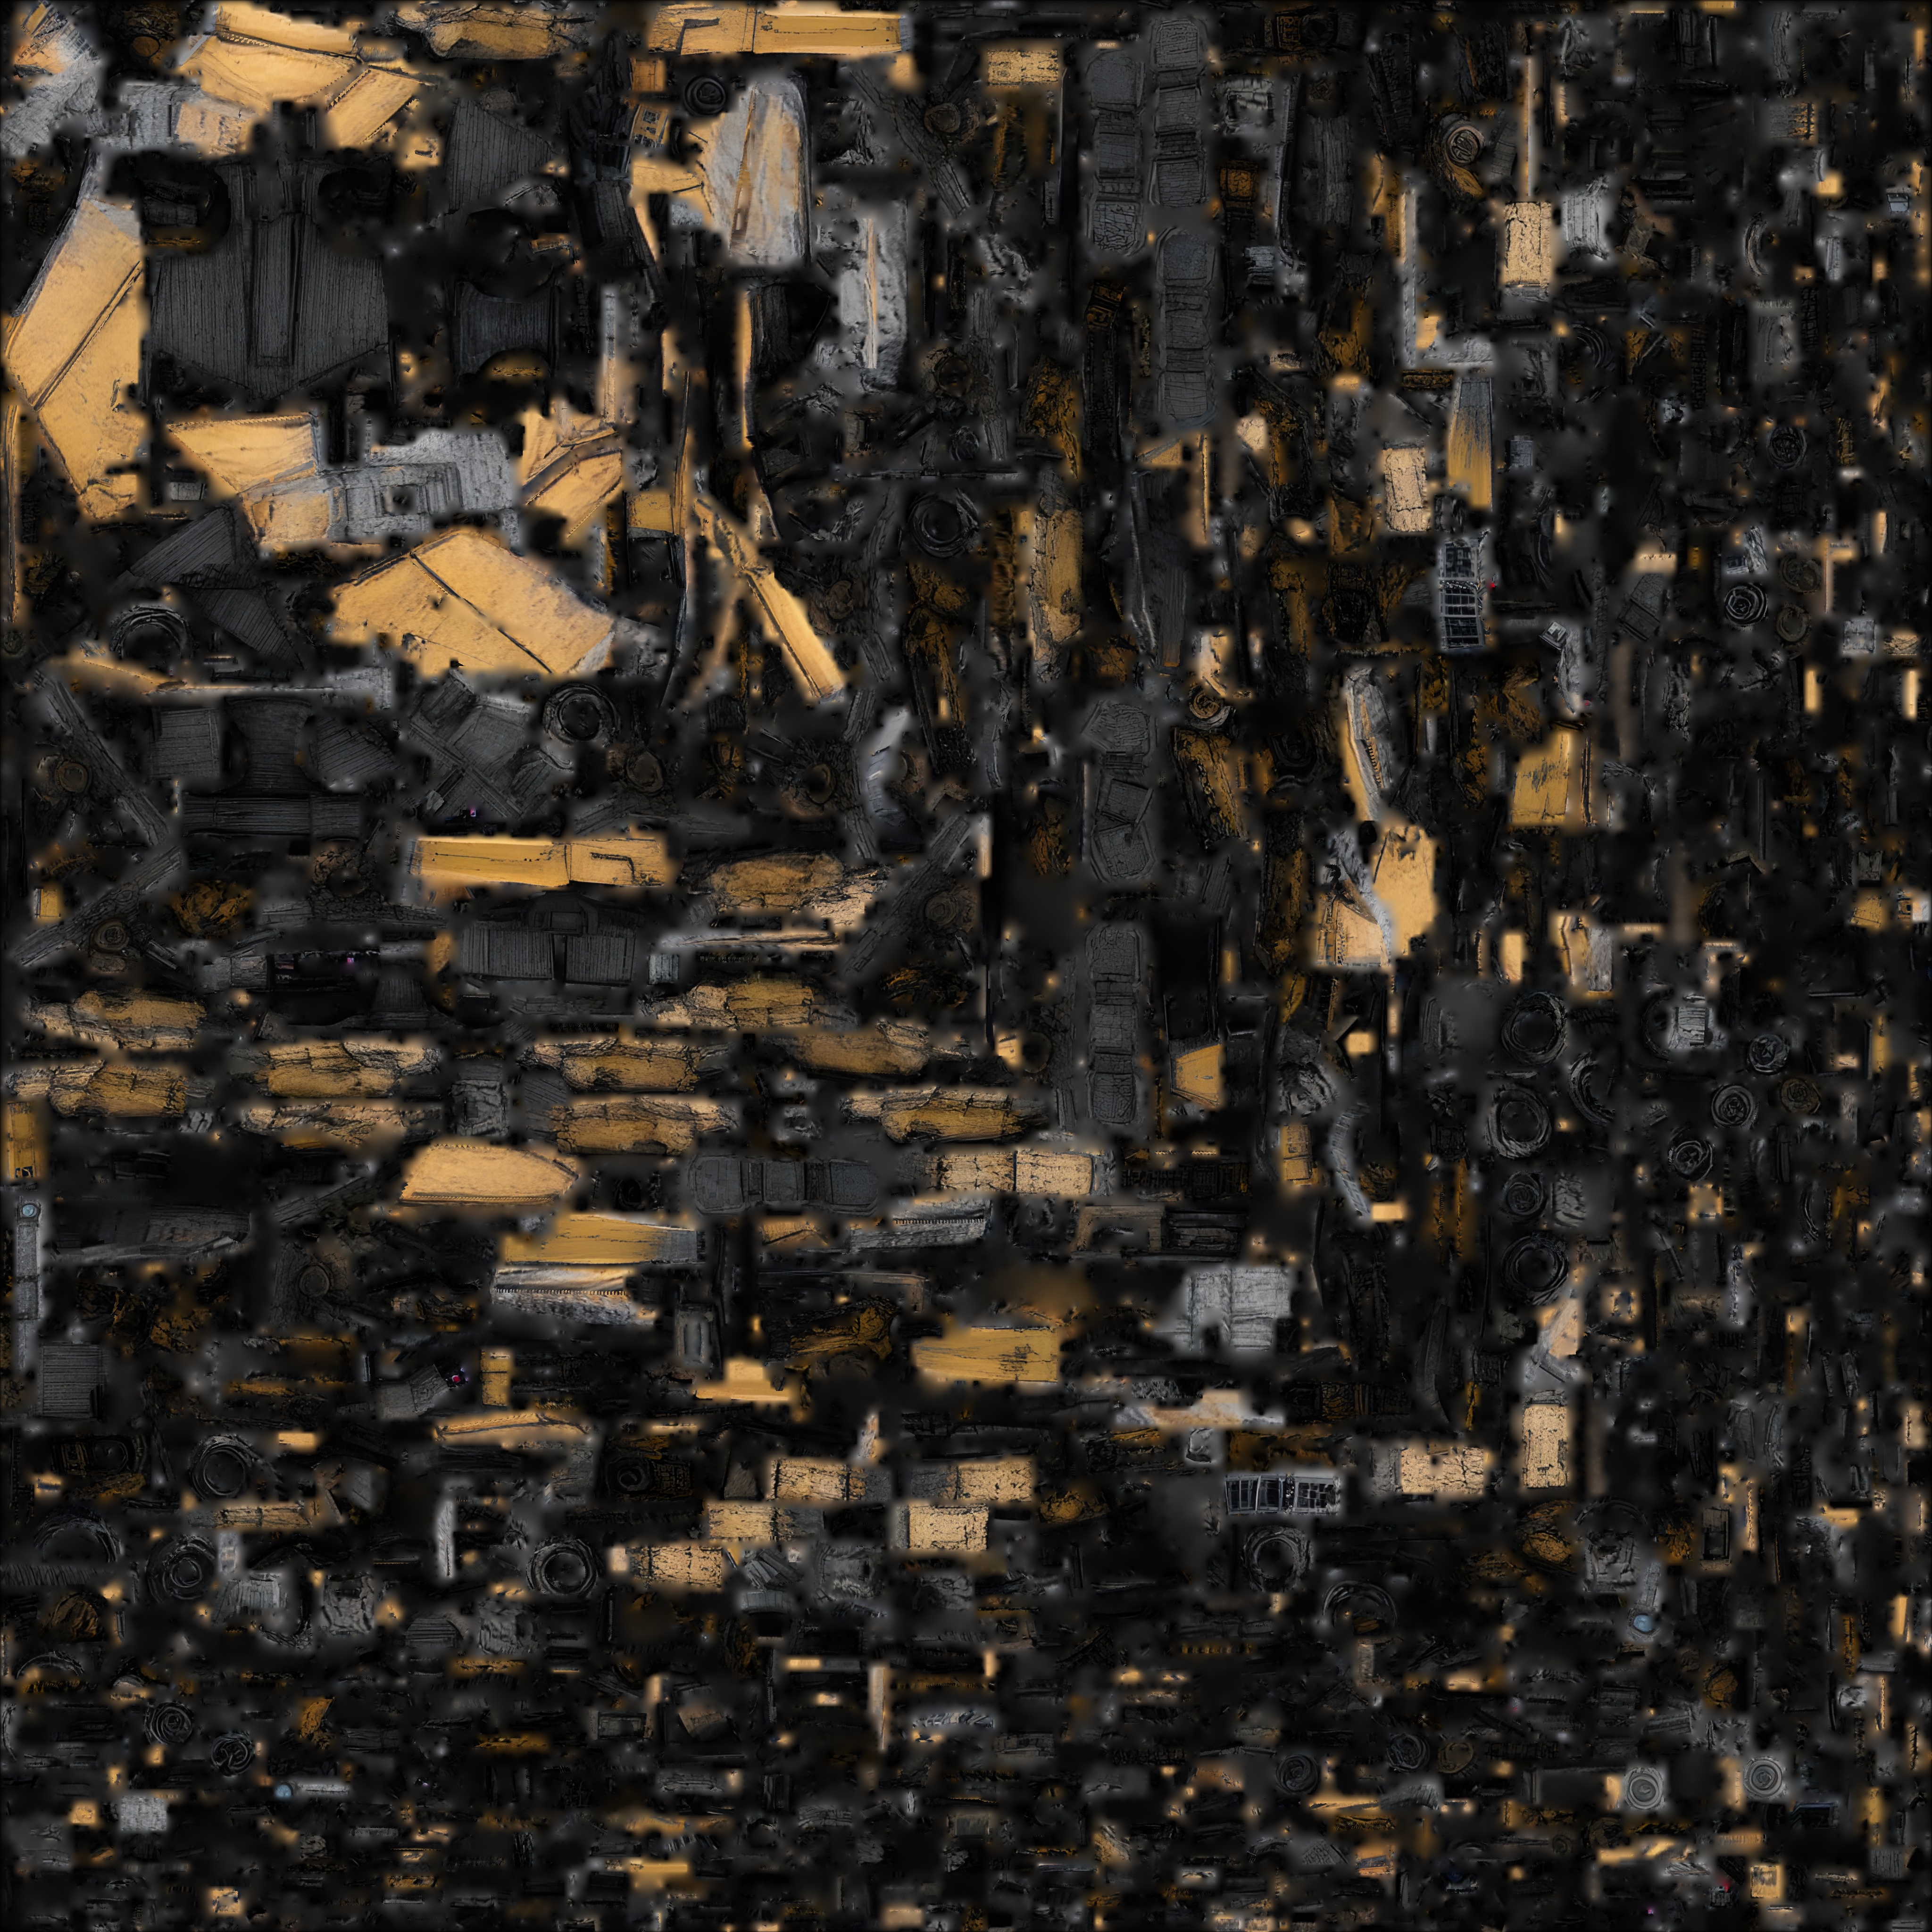
Base-color texture atlas extracted from the Basilisk drone model.
Texture map · Extracted from the generated model.

05WebGL render

Animated model · Video rig with symmetry checks + simulated equipment inertia.

Reference ↑
LOADING 3D
BASILISK DRONE
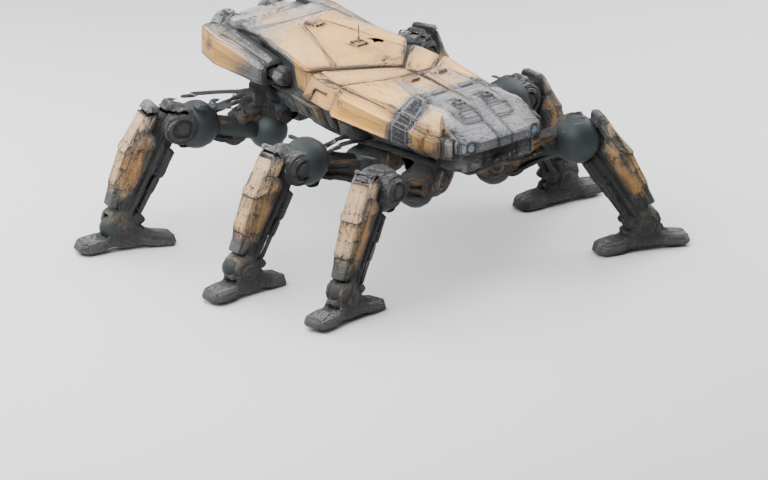
Preview of the reconstructed Basilisk drone model.

3D preview · Rendered from the generated mesh.

Loading the animated model…

Drag to orbit · Scroll to zoom
0.0 / 8.0 s

Fictional mechanical gait. Hidden joints, contact timing and equipment dynamics are inferred.

Shared technique

ImageGen creates the reference; Kling supplies motion; Hunyuan 3D builds the complete mesh. Tracking guides the skeleton and any cuts needed for articulation. Joints and ground contact constrain the movement; Three.js renders the result.

New studies use natural scenes and markerless tracking, with SAM 3 separating subject from background. The earlier Lystrosaurus suit and Tiktaalik green screen remain as experiments.

This is a reconstruction workflow. Generated video, inferred geometry and assumed material properties cannot establish biological accuracy or physically optimal motion.

Rigging choices
Lystrosaurus · Continuous skin
The skin is continuous across the torso, limbs, neck and tail. Separate rigid body pieces would produce seams and prevent natural skin and belly deformation.
Tiktaalik · Continuous skin
The fish-like trunk, tail and fin membranes form a continuous deformable surface. Fin rays and body bends need their own controls without breaking the skin into rigid pieces.
Dreadnoughtus · Continuous skin
Continuous skin connects the long neck, trunk, tail and limbs. Many vertebral and tissue controls should deform one body surface without mechanical seams.
Basilisk drone · Rigid pieces cut from the mesh
Start with the complete mesh. Cut armor, leg links, pads and equipment at structural joints where they need to move independently, keeping each piece rigid and its attachment intact.
Hunter-killer drone · Skin + rigid attachments
Generate the entire four-arm cyborg as one mesh. Keep the living torso continuous; cut the four armored insect-like arms, pincer segments, rotor outriggers, ducts and gun housings at their mechanical joints during rigging.
Cheetah · Continuous skin
A continuous spotted surface bends at joints, with structural supports for the rib cage, pelvis, skull and limb cores.

Generate the whole mesh first. Keep skin continuous; cut rigid pieces where joints require separate movement. Mesh pieces never limit skeleton detail.

Catches + fixes

Hidden motion and missing depth
Overlapping limbs can confuse tracking, and one view cannot reveal depth. Uncertain observations are filtered out; hidden limbs are reconstructed from the visible motion. Those inferred poses remain distinct from observed tracks.
Different bodies need different constraints
Each rig preserves segment lengths and adapts support to its body. The Basilisk drone gives every supported motion group its own control and keeps its metal parts rigid. Repeatable motion adds controls. Basilisk’s paired limbs share dimensions and attachments; body controls follow its long axis. Offsets from that axis require an explicit reason tied to the reference.
Snapping joints and uneven steps
Dreadnoughtus’s knees and elbows flipped bend direction during a stride. Stable bend directions, slight rear-knee flexion, smooth foot lift and landing, and a continuous final partial step corrected those jumps.
Secondary motion needs separate treatment
Damped inertia adds lag to bellies, tails, long necks, fin rays and mounted equipment. It responds to the fitted movement while preserving the primary gait; the physics toggle reveals the added motion.